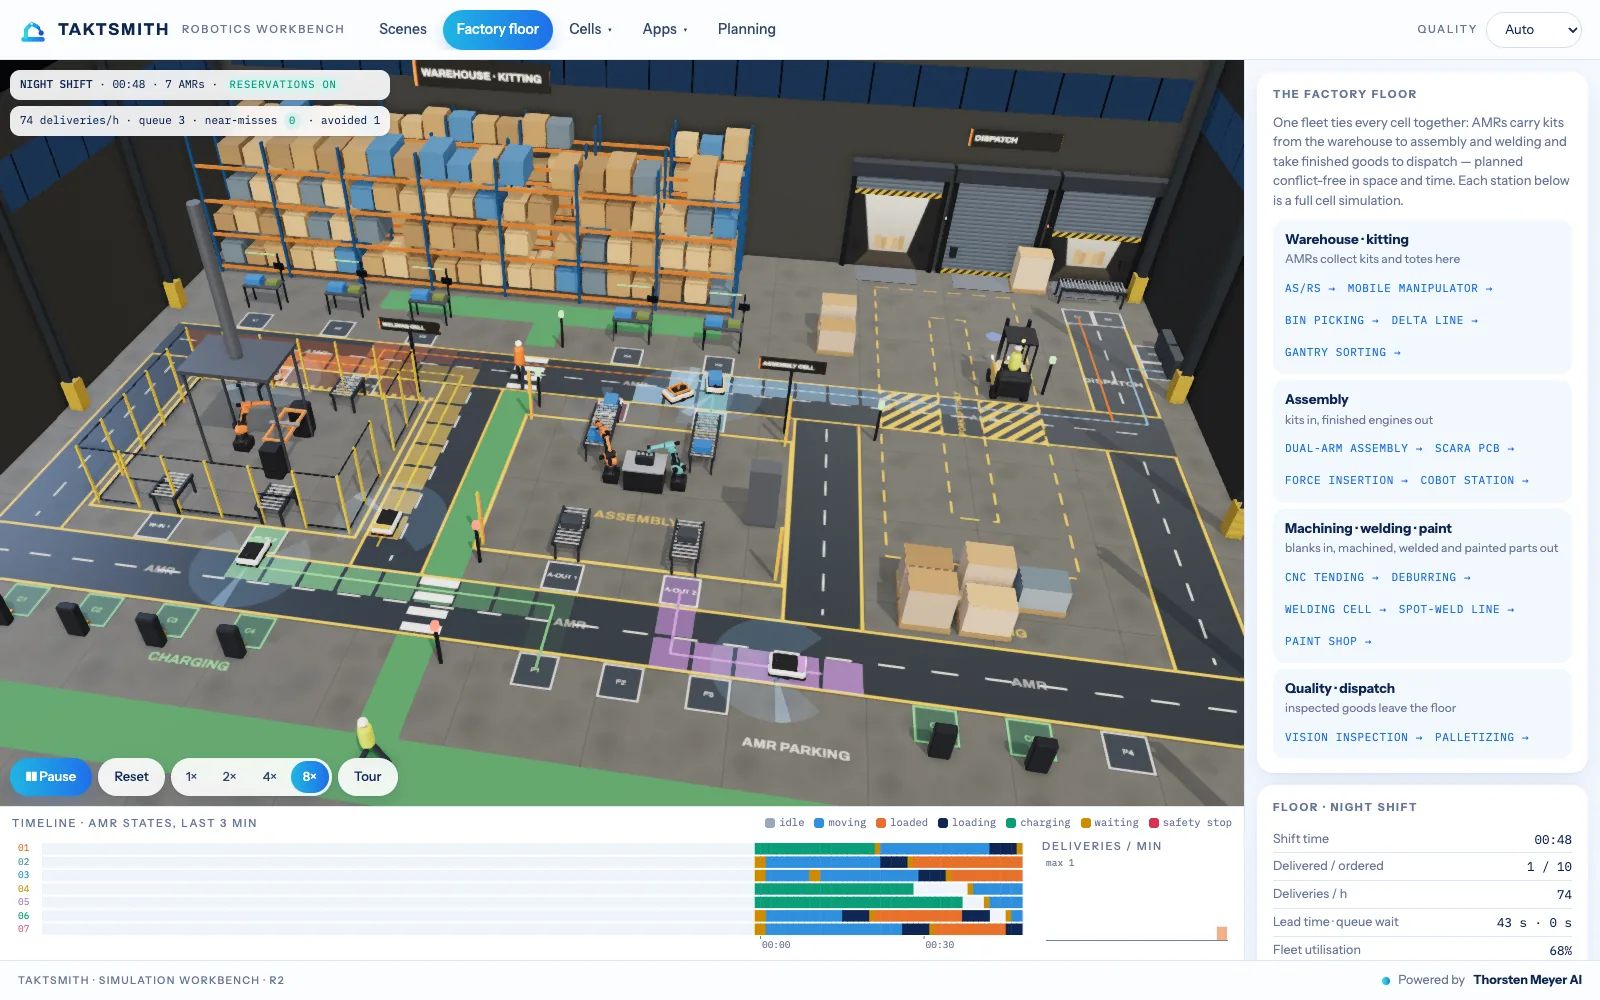
Orders by auction
Kit deliveries, finished engines and empties become orders. Idle AMRs bid with travel time, battery and load — the best-placed robot wins.
Taktsmith · the factory floor
Plan and simulate a whole robotic factory floor in the browser: an AMR fleet that carries kits from the warehouse to the cells and finished goods to dispatch — every route conflict-free in space and time, around people and forklifts.
Runs in your browserExports IFC4 · ROS 2 · robot codeStatus free preview
What goes in
 TAKTSMITHplans the robotic factory floortaktsmith.com
Orders by auction · space-time reservations · safety fields
What comes out
Key facts from a simulated 10-minute night shift.
How the fleet plans
Shortest paths are easy. Seven robots, a forklift and people crossing the aisles at the same time are not. Taktsmith plans the fleet the way the cells plan their arms.
Kit deliveries, finished engines and empties become orders. Idle AMRs bid with travel time, battery and load — the best-placed robot wins.
Each AMR plans against a shared reservation table: no two robots in the same cell at the same moment, no head-on swaps, waits allowed. Conflicts are prevented, not detected.
Humans and forklifts are dynamic obstacles inside each AMR's safety field; low batteries send robots to charge before they strand. Switch reservations off and watch the near-misses appear.
Stations on the floor
Every station is a working simulation of its own — with the same core: kinematics, time-parameterised motion, task graphs, reservations and safety monitoring.
Warehouse · intralogistics
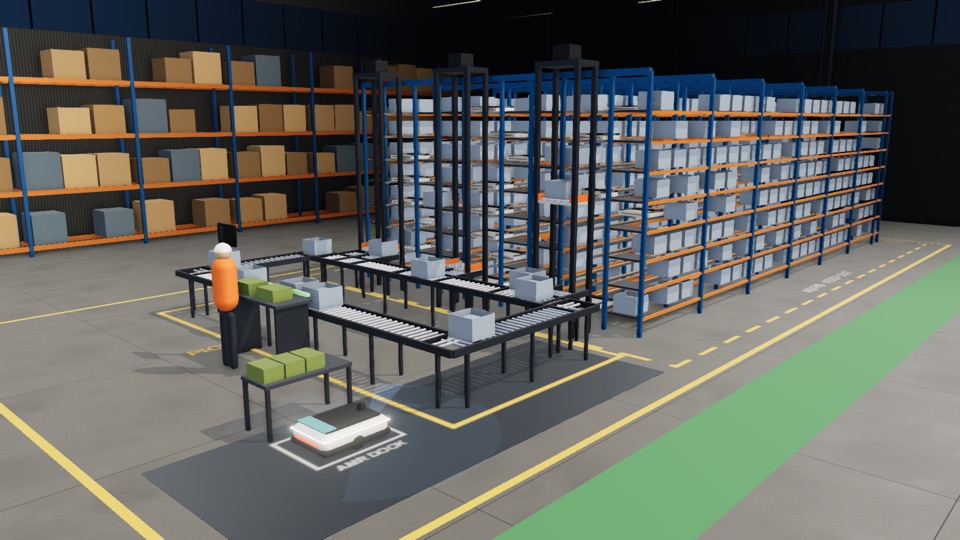
Shuttles and lifts store totes; storage strategy vs the lift bottleneck.
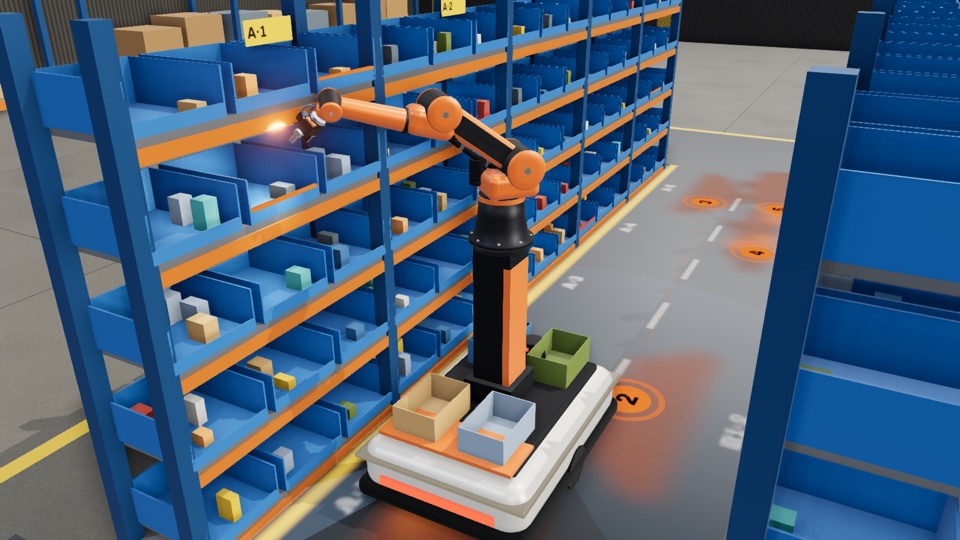
An AMR with an arm picks from shelves — base placement from a reachability map.

Depth camera and learned grasp scoring empty a bin of mixed parts.
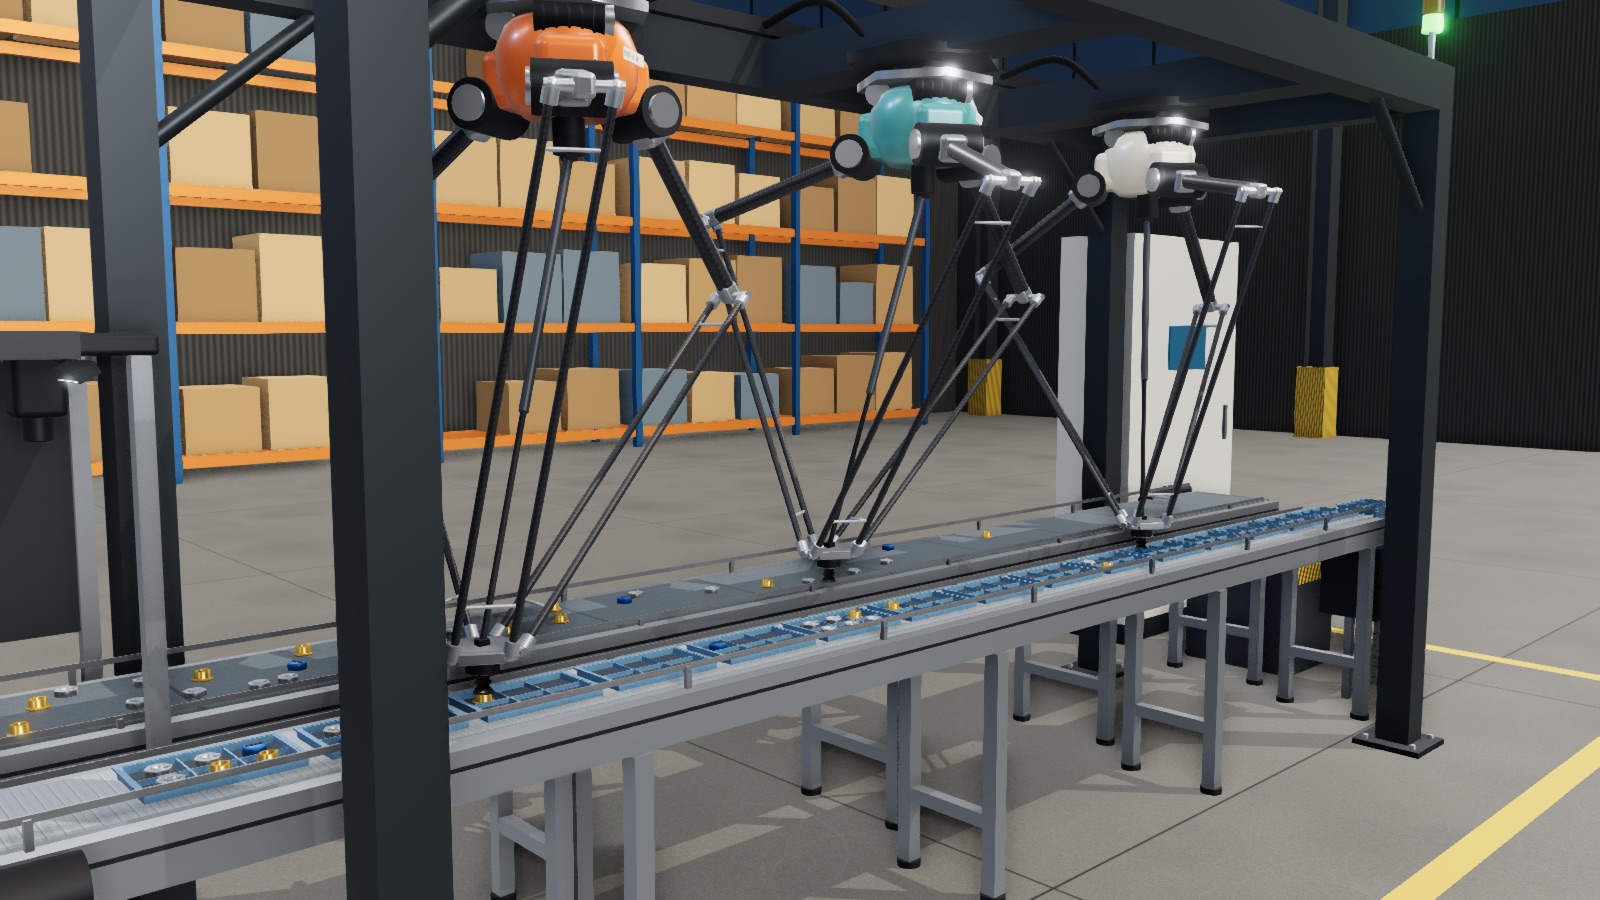
Three delta robots pick parts off a moving conveyor and share the load.
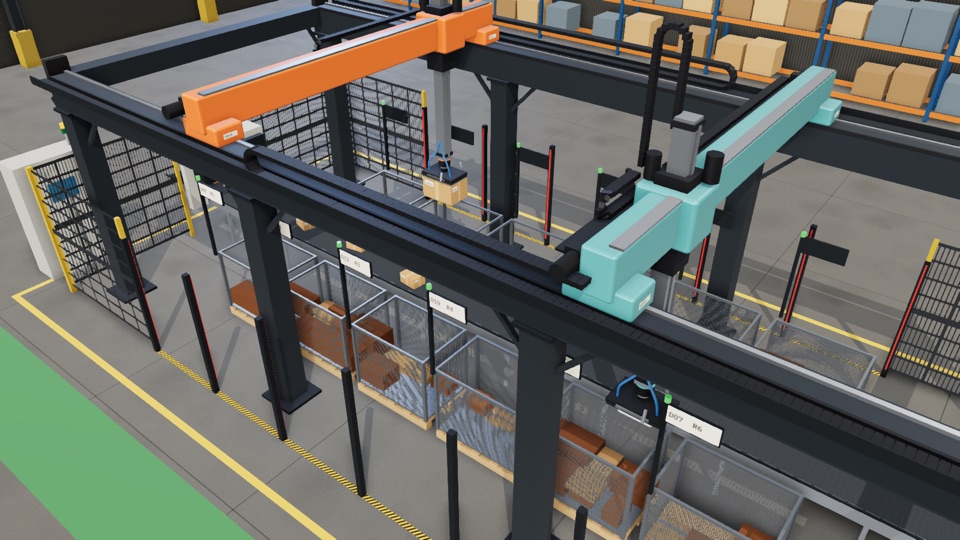
Two gantry bridges share one beam to sort parcels into destinations.
Assembly · electronics
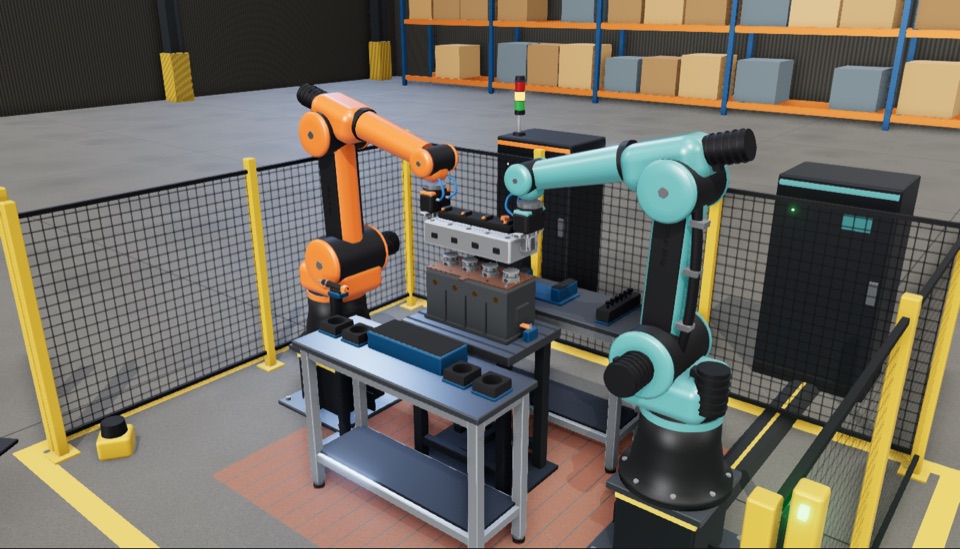
Two arms build an inline-4 short block: cooperative carry, handover, spiral torque.
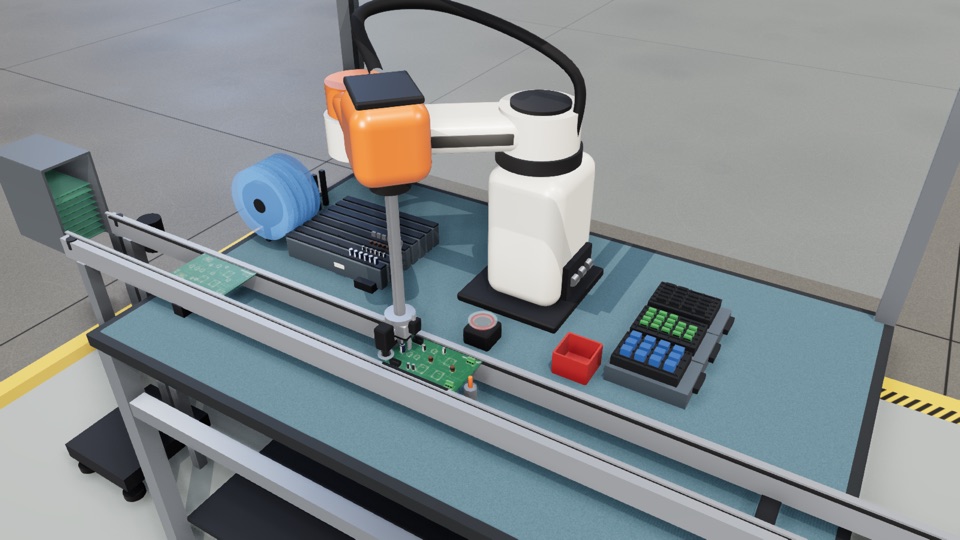
SCARA kinematics, vision alignment and placement-sequence optimisation.

Peg-in-hole with impedance control and spiral search.

A cobot shares the bench with a person — speed & separation monitoring.
Machining · body · paint
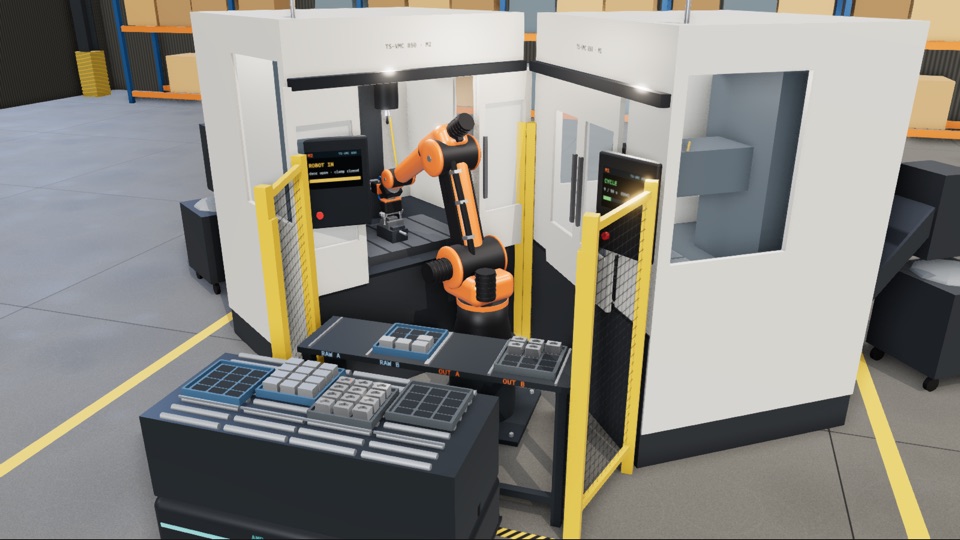
One robot serves two machining centres — when does the robot become the bottleneck?
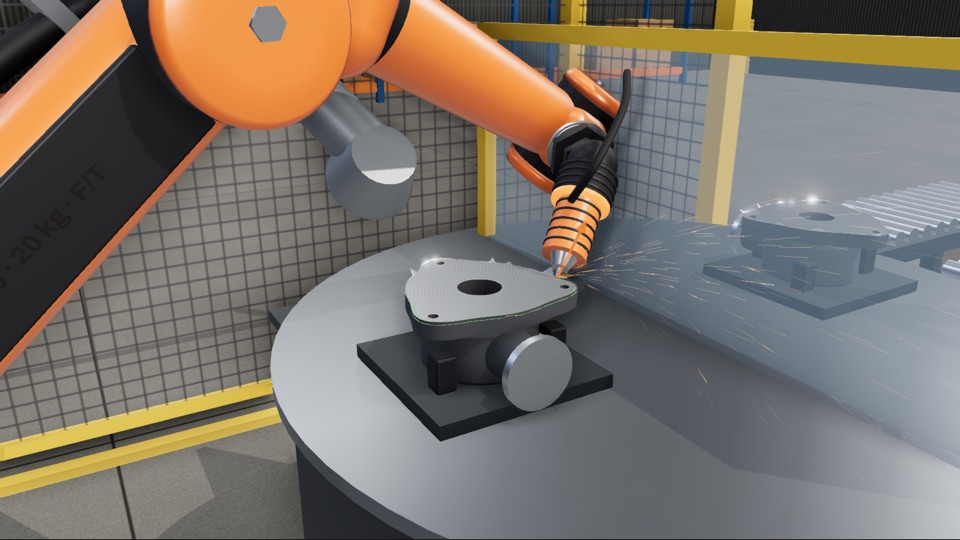
Force-controlled edge following: 96 % in tolerance vs 67 % position-only.
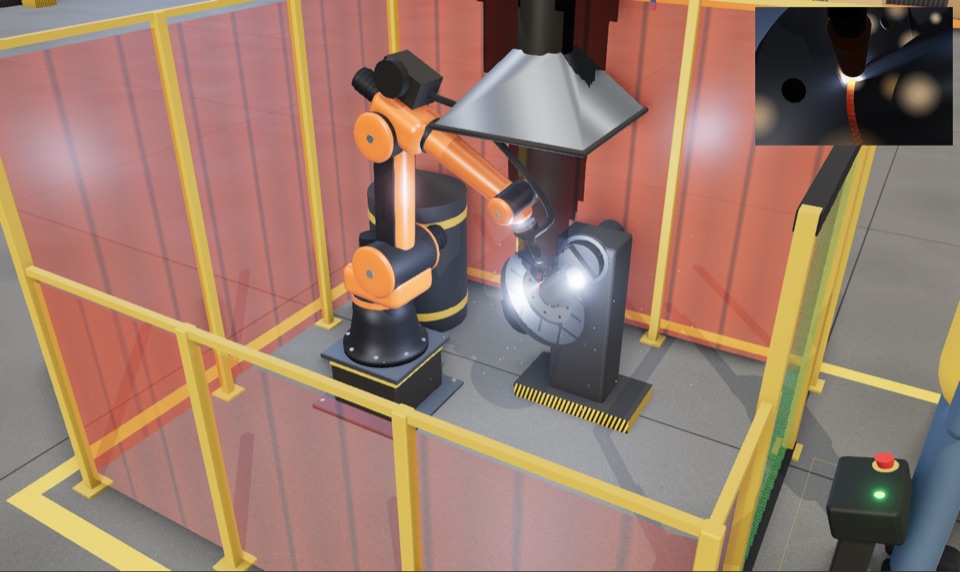
Seam finding, multi-pass welding, a handler robot, robot-code export.
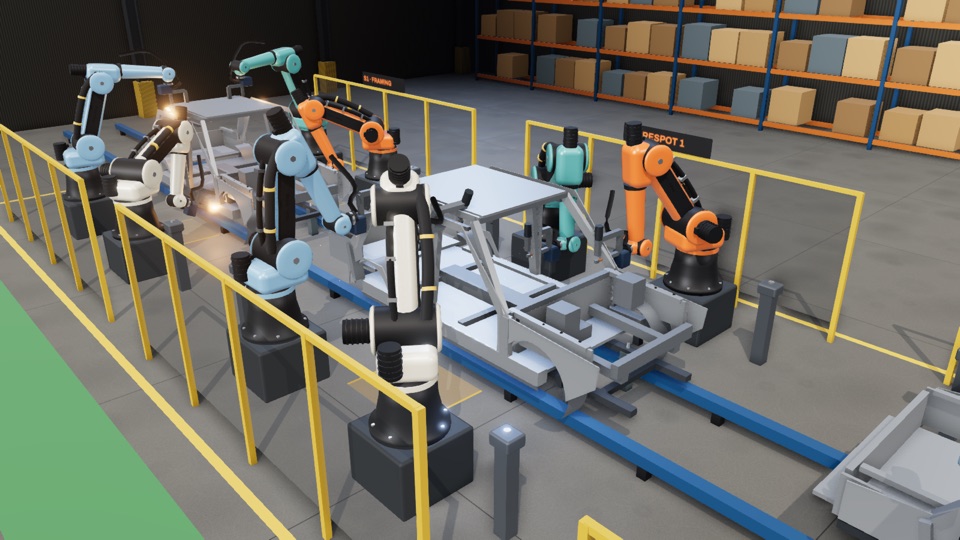
Body-in-white stations: weld-spot allocation and interference zones set the line takt.
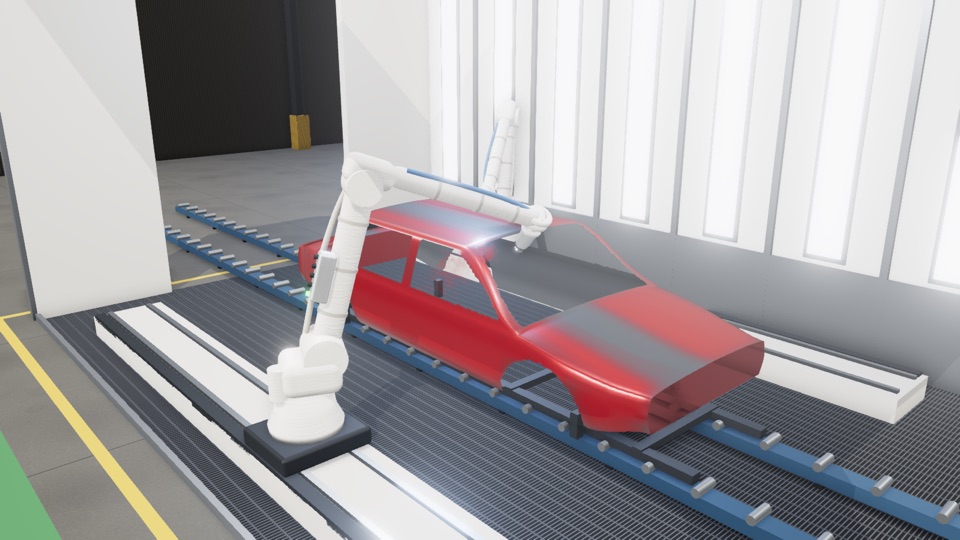
Spray-path planning with a film-thickness model: uniformity vs paint usage.
Quality · dispatch
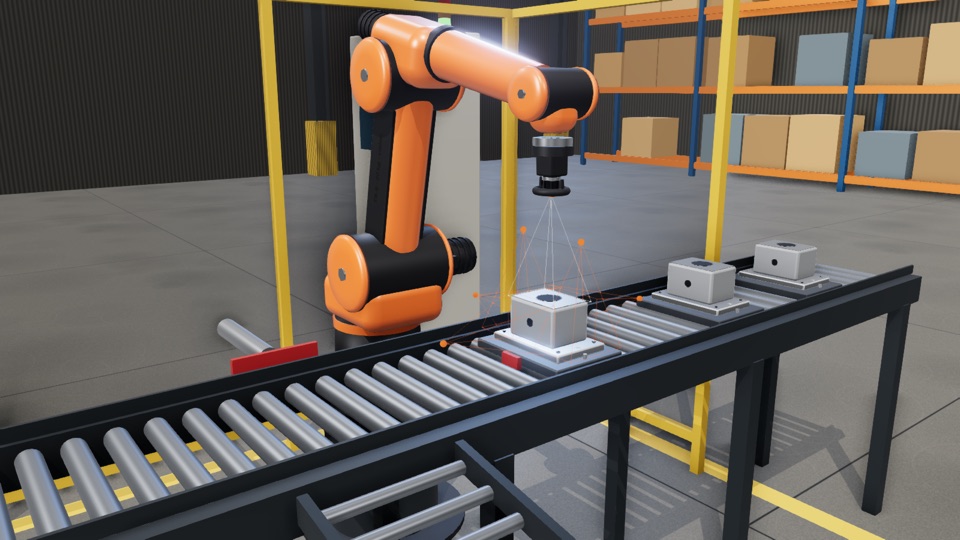
Viewpoint planning, measurements and SPC with honest false-reject trade-offs.
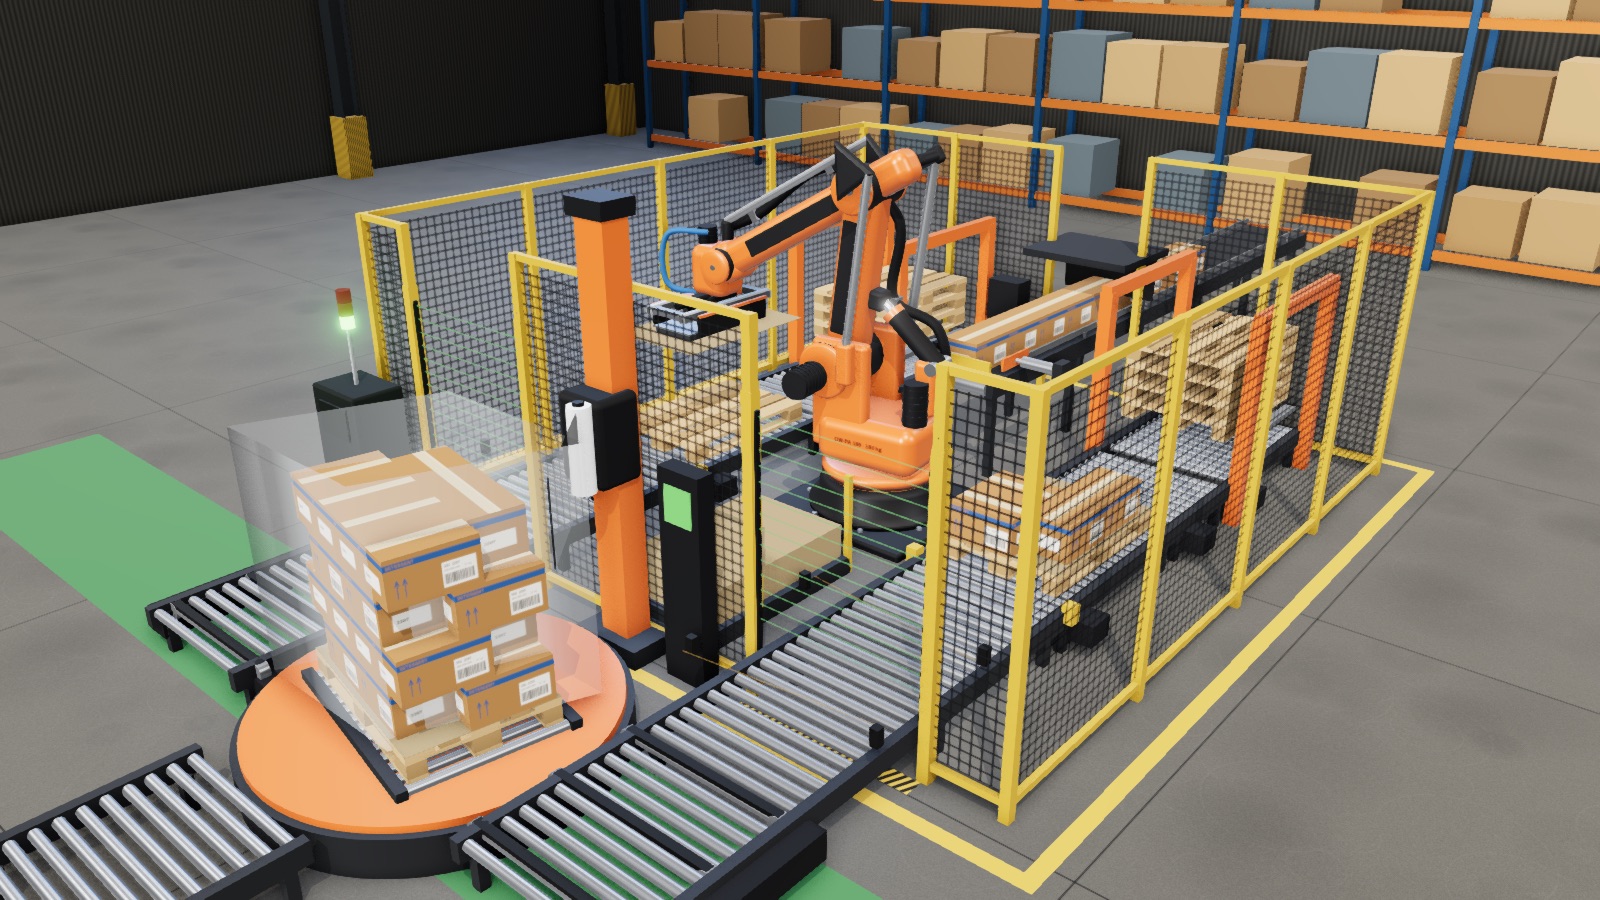
Interlocked layers and pallet swap without stopping the line.
Beyond the factory · construction site
Engineering apps
Lay out the hall, balance the line, size the robot, check the safety distances, make the business case.
Drag & drop cells, racks and aisles; checks and IFC export.
AppTasks, precedence and takt time → stations and efficiency.
AppPayload, reach, precision, budget → ranked robot classes.
AppISO 13855 / 13857 and ISO/TS 15066, drawn to scale.
AppPayback, NPV, IRR and sensitivity of a robot investment.
AppSix parametric gripper mechanisms → CadQuery, OpenSCAD, FreeCAD, STL.
Hand-off